Autonomous Vehicle 3D Vision Detection
Deployed the BEVFusion hybrid camera-LiDAR object detection model for Ford Otosan's ADAS team.
TL;DR: Evaluated and deployed the BEVFusion 3D vision detection algorithm for the Advanced Driver-Assistance Systems (ADAS) team at Ford Otosan.
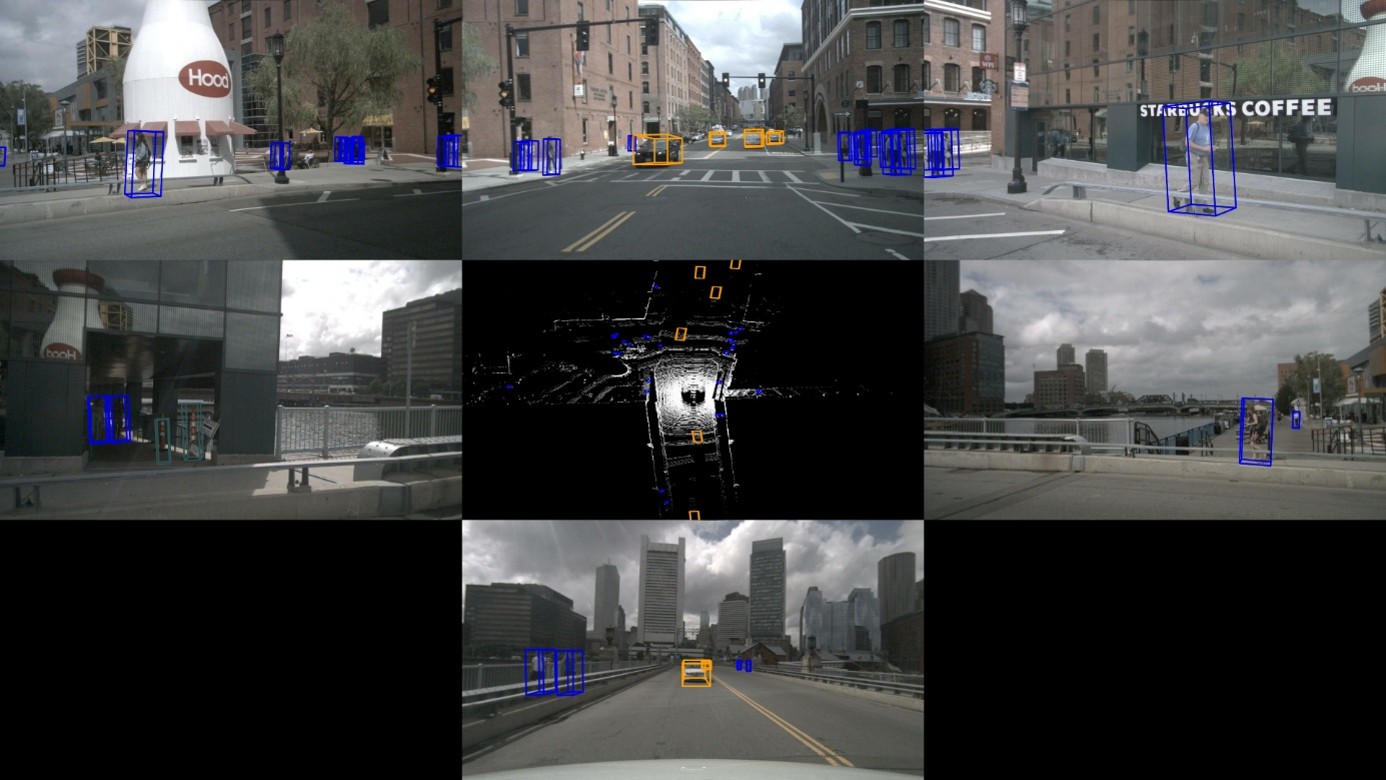
Technologies & Methodology
- Hardware: NVIDIA T4 GPU, Google Cloud Virtual Machines, and remote SSH servers.
- Software & Frameworks: Python, Nvidia Toolkit 11.1, TensorRT, and Netbird.
- Algorithms & Datasets: BEVFusion (hybrid camera and LiDAR inputs), nuScenes (v-1.0 mini) dataset.
Key Contributions & Results
- Conducted an extensive literature review covering monocular, stereo, multi-camera, and fusion-based 2D and 3D vision detection architectures.
- Resolved library dependency conflicts and repaired repository code to successfully execute BEVFusion inference for 3D object detection and Bird-Eye-View (BEV) map segmentation.
- Overcame local GPU memory constraints by configuring a remote SSH connection via Netbird and deploying a Google Cloud virtual machine to process the models.
- Authored comprehensive technical documentation detailing the inference pipeline, visualization steps, and troubleshooting procedures for CUDA and TensorRT acceleration.